Projects
Industry
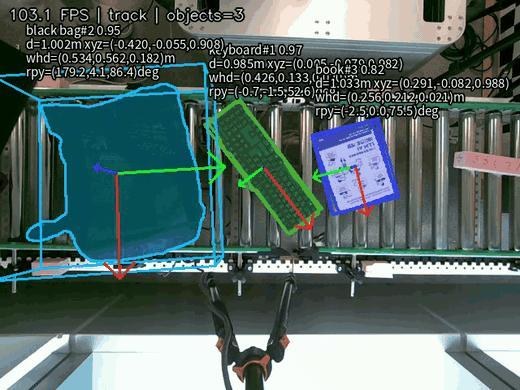
Zero-Shot Object Recognition & 3D Pose Estimation
Detect and track arbitrary objects from a text prompt, publish RGB-D 3D pose with confidence over ROS2 — no retraining, no CAD, 9–13 FPS.

Gaussian Splatting XR Space Reconstruction & Localization
Space assets and indoor localization in one coordinate frame, via 360° video and RGB-D SLAM — 123 FPS rendering, 100% global relocalization at 62.8 FPS.

Drawing-Based Interactive Character
Auto-rig hand drawings and drive them with the user's body motion, facial expressions, and speech in real time — talking video generation 4.8→2.1 s.
Research

Hybrid LLM Navigation System
Context-aware ROS2 navigation that selects driving policies in crowded environments — 82% vs 43% goal-arrival success over the Nav2 baseline.

MobileViT Motorcycle Traffic-Violation Detection
Temporal traffic-event recognition with YOLO and MobileViT, deployed in real time on a Jetson Orin NX.

ROS2 UGV Platform Integration
Autonomous-driving platform integration for an unmanned ground vehicle: sensors, CAN communication, SLAM, and navigation.

LLM-Assisted Strawberry Quality Assessment
Smart-farm system linking segmentation and quantitative image analysis to RAG and LLM-generated quality reports.